Embodied AI
Navigation agents that combine perception, memory, reasoning, and action in interactive environments.
Hi, I am a second-year Ph.D. student at the Australian Institute for Machine Learning (AIML), Adelaide University, supervised by A/Prof. Qi Wu and A/Prof. Jiajun Liu. I am a member of the Vision and Visualisation for Autonomous AI Lab (V3A Lab), where I work on embodied AI, vision-language reasoning, and autonomous agents.
Prior to my Ph.D. studies, I received my Master’s degree from the University of Adelaide, now Adelaide University, where I was mentored by Dr. Gengze Zhou. Since 2026, I have been focusing on agentic AI for embodied AI tasks under the mentorship of Dr. Gengze Zhou and Dr. Sihao Lin. I also collaborate closely with Jian Zhou, Zerui Li, and Dr. Shijie Li.
My research focuses on building explainable and embodied AI systems for autonomous agents that can perceive, reason, learn, and navigate in complex 3D environments. I am particularly interested in evaluating and improving multimodal large language models for 3D understanding, spatial reasoning, lifelong learning, and ultra-long-horizon vision-and-language navigation. Recently, I have been exploring agentic AI frameworks for embodied tasks such as VLN, aiming to integrate perception, reasoning, memory, and decision-making into unified autonomous systems. More broadly, I am dedicated to bridging the gap between simulator-based embodied AI research and real-world robotic applications.
I open-sourced SurveyAtlas (code), a living literature survey: LLM agents harvest, classify and deep-read a field's papers, verify the reported results, and publish a searchable website with Q&A, a research map and leaderboards. The first atlas, NavAtlas, covers 3,000+ embodied-navigation papers.
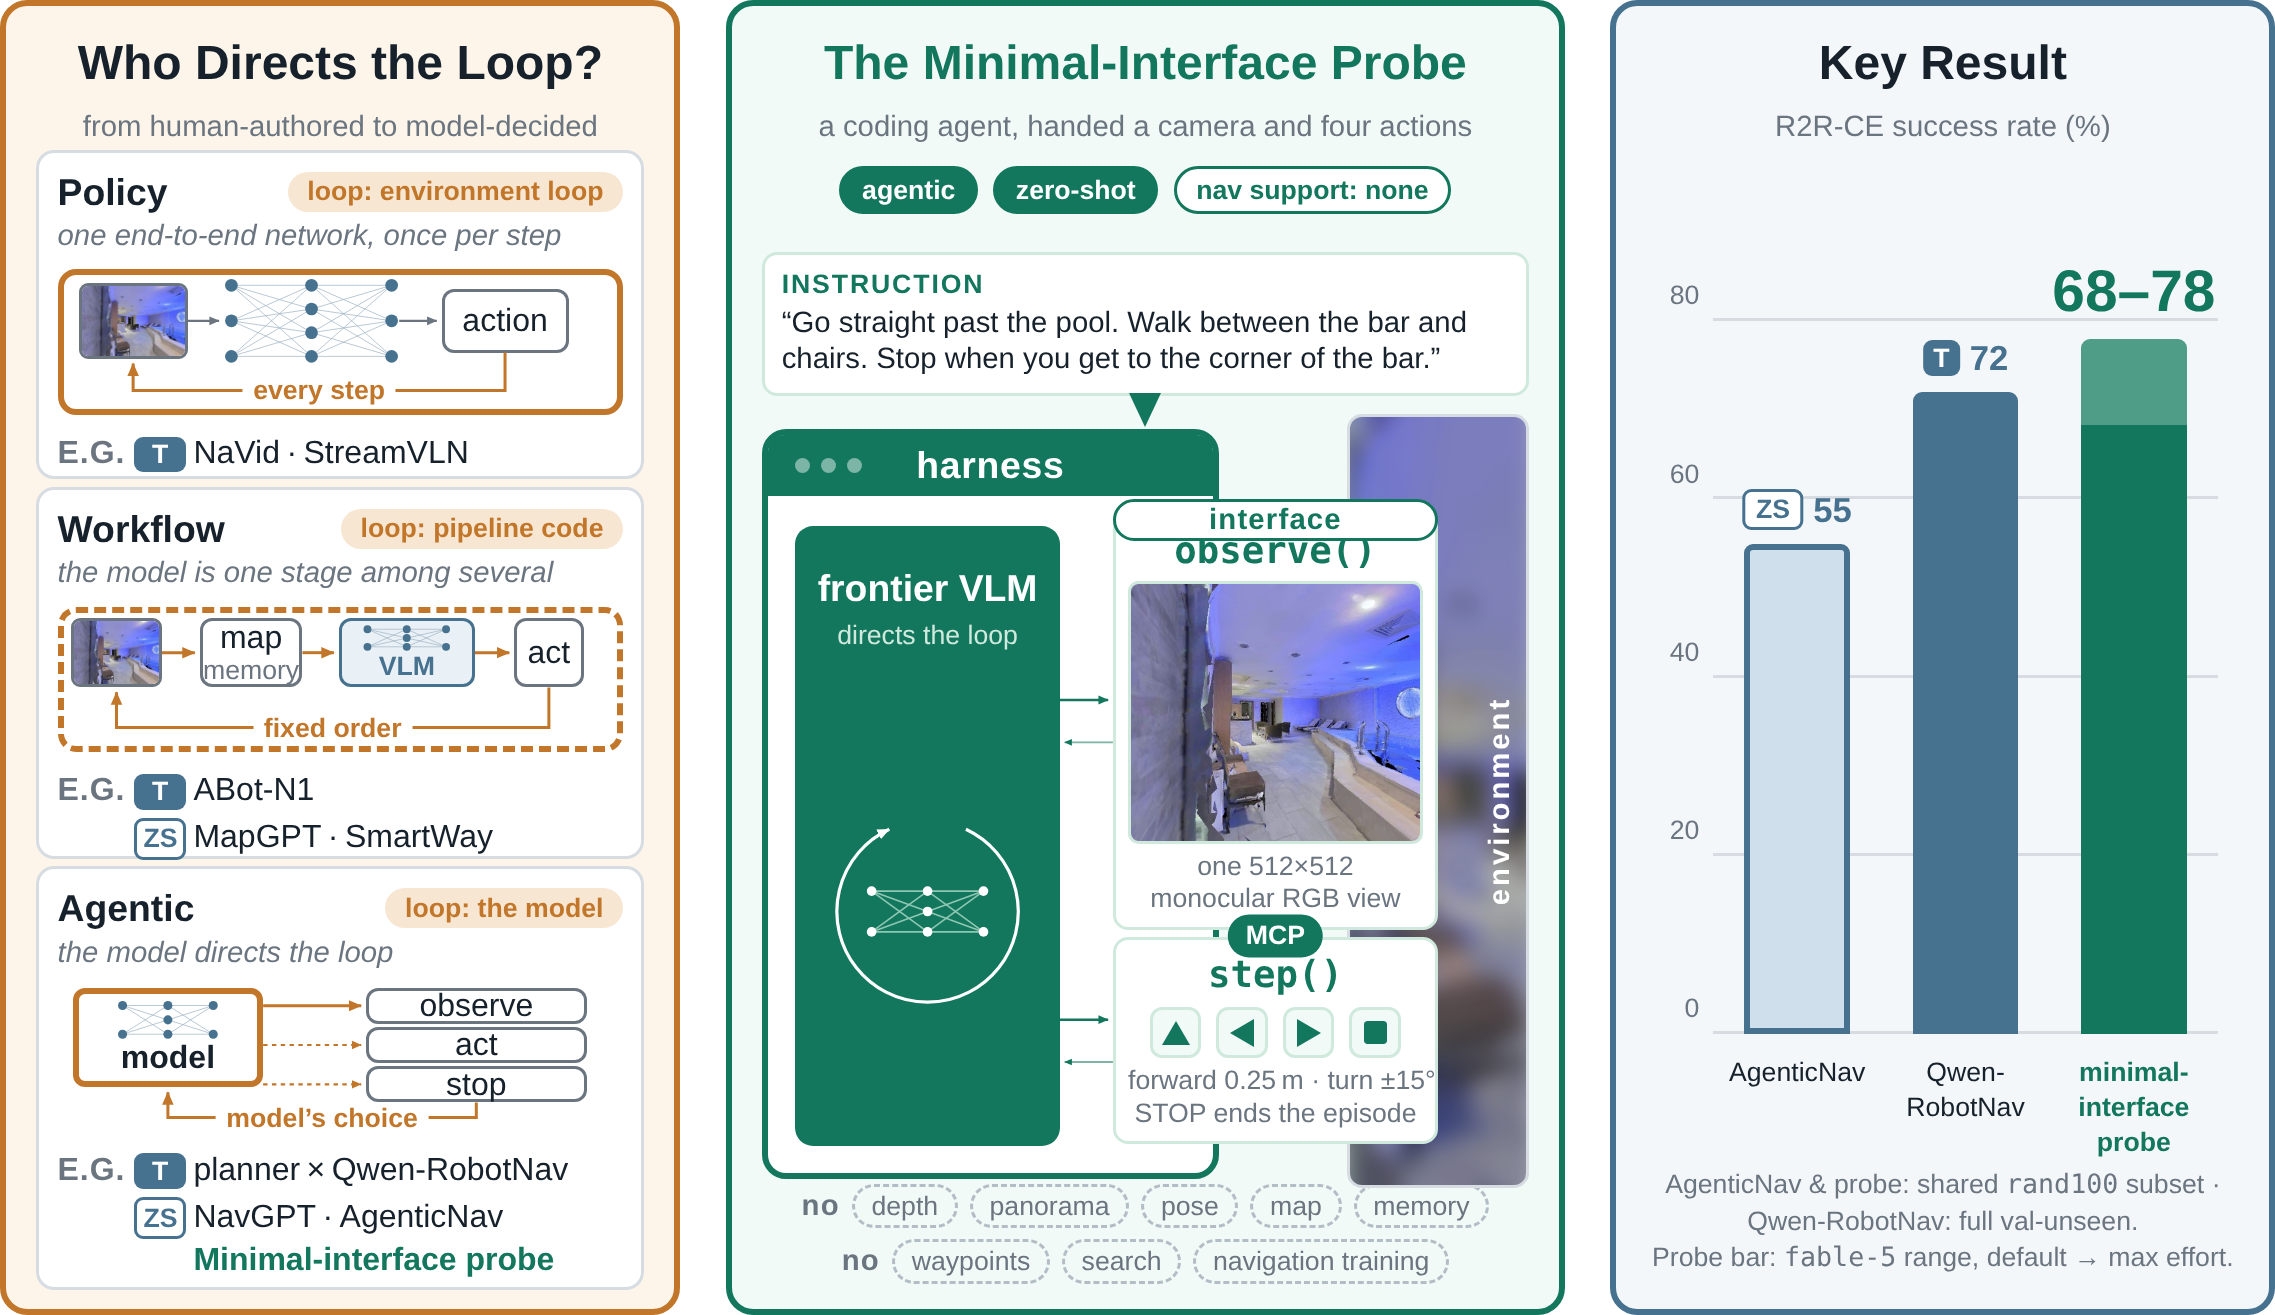
Our new preprint Embodied Agents Take Control is out on arXiv! Given only a monocular RGB camera and four discrete actions, a general-purpose agent already rivals industrial-scale navigation policies on VLN.
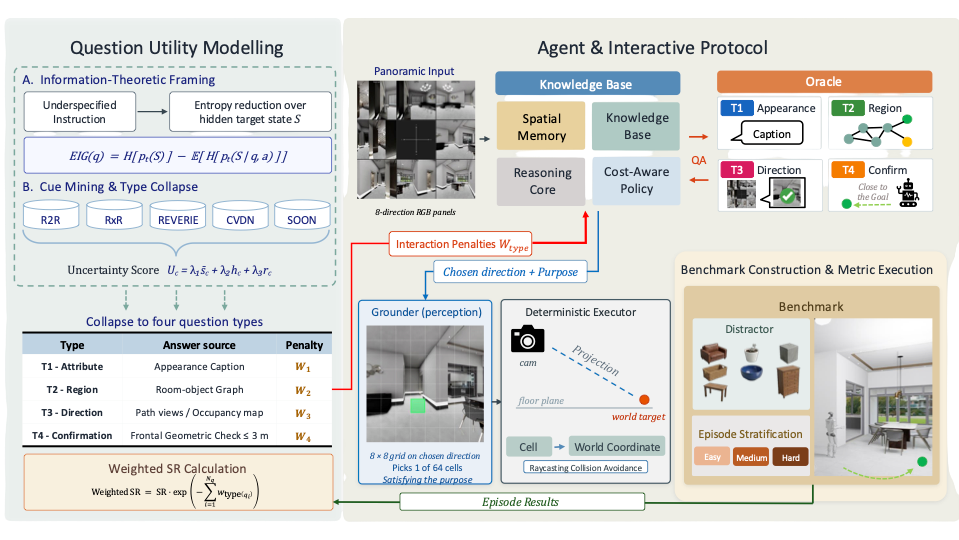
Our new preprint Ask When It Pays is out on arXiv! It is a cost-aware reactive agent for instance goal navigation that works out when asking a question is worth what it costs. My first attempt at building a ReAct-style agent.
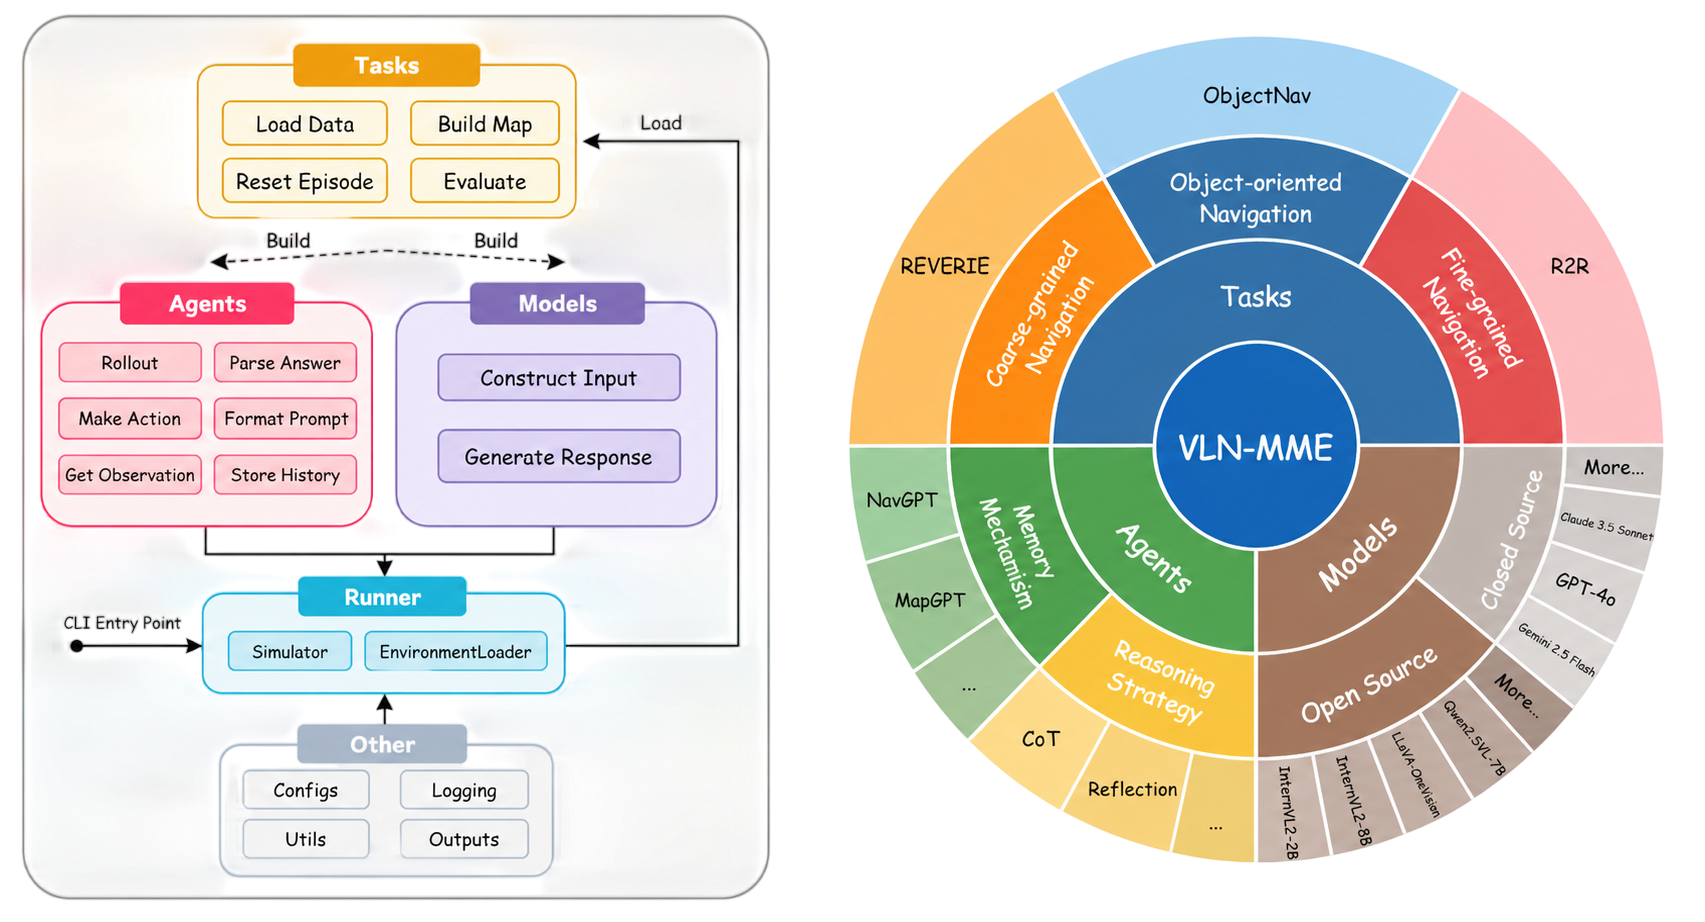
My first Research Paper VLN-MME is accepted to ACL 2026! Many thanks to my mentor Gengze, for his invaluable guidance and support.
My first co-authored project, VLNVerse is now released!
I have started my PhD at the University of Adelaide.
Navigation agents that combine perception, memory, reasoning, and action in interactive environments.
Large vision-language models for long-horizon planning, question answering, and scene understanding.
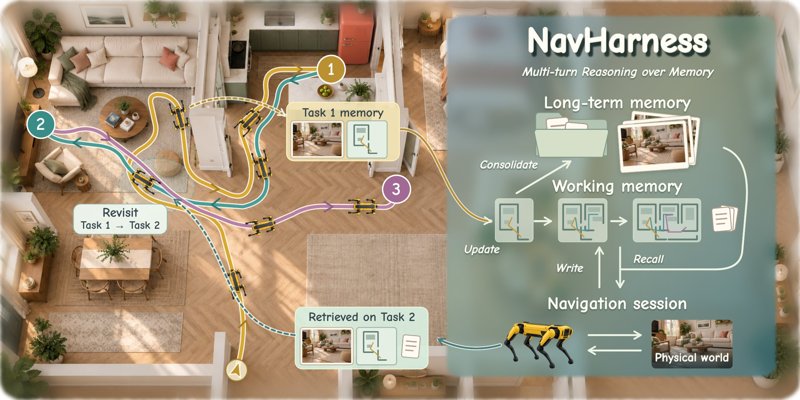
Vision-language navigation agents that use multimodal observations, natural-language instructions, and step-by-step reasoning to plan actions in embodied environments.
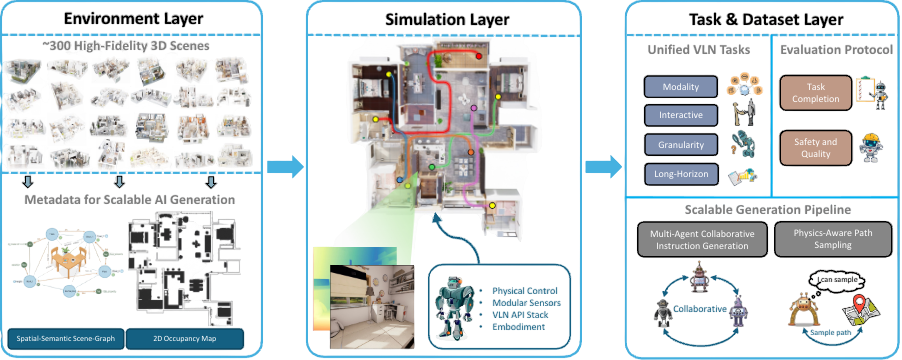
Open-source tools I build and maintain.
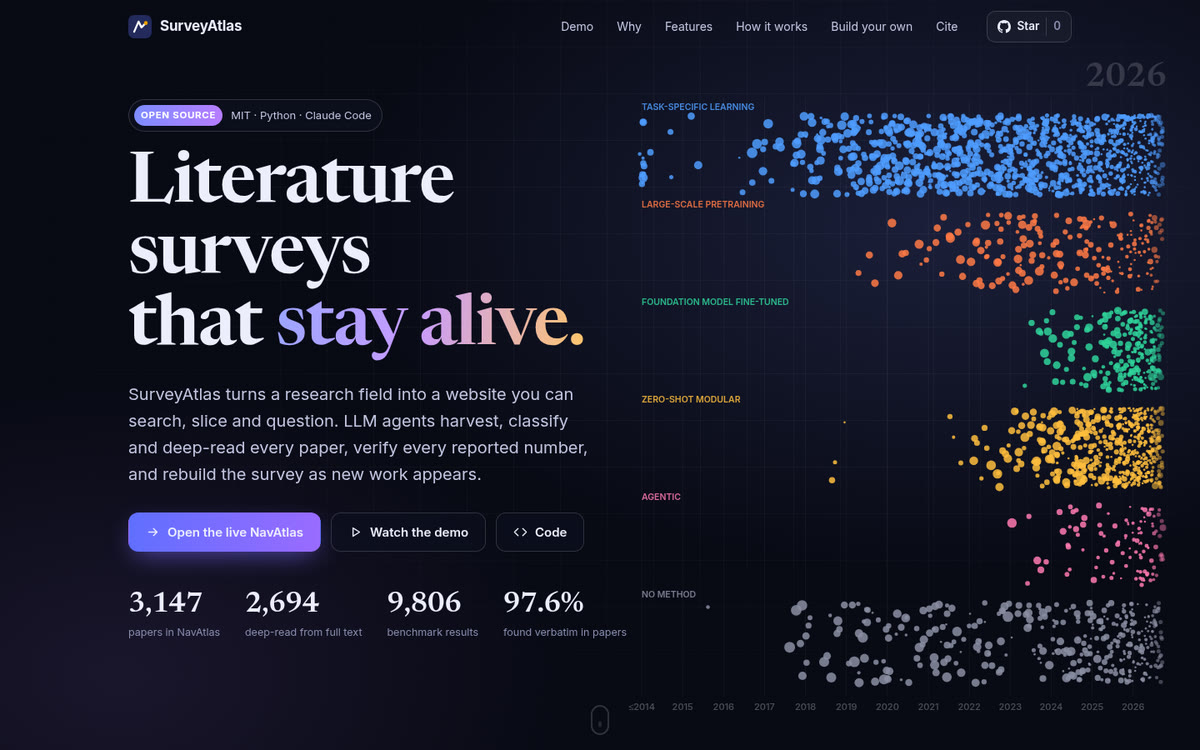
Turns a research field into a self-updating survey website. LLM agents harvest arXiv and OpenAlex, classify papers into a field taxonomy, deep-read them and check every reported number against the paper text. The site offers a faceted library, Q&A with citations, a task × paradigm map, a timeline and protocol-aware leaderboards, and rebuilds itself every day. NavAtlas, the first atlas, covers 3,147 embodied-navigation papers.
COMP 5004 - Programming for Artificial Intelligence and Machine Learning
COMP 6004 - Deep Learning Applications
INFO 2005 - System Design